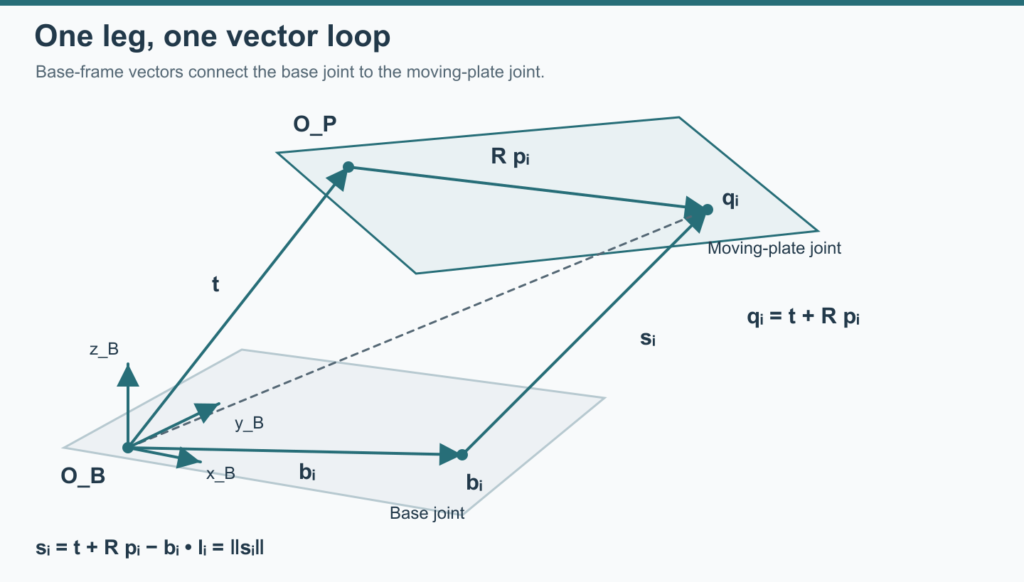
Stewart Platform Kinematics: Inverse and Forward Solutions, Step by Step
Derive Stewart platform leg-length equations, follow a numerical example, and understand forward-solution checks and the limits of a geometric model.

Derive Stewart platform leg-length equations, follow a numerical example, and understand forward-solution checks and the limits of a geometric model.
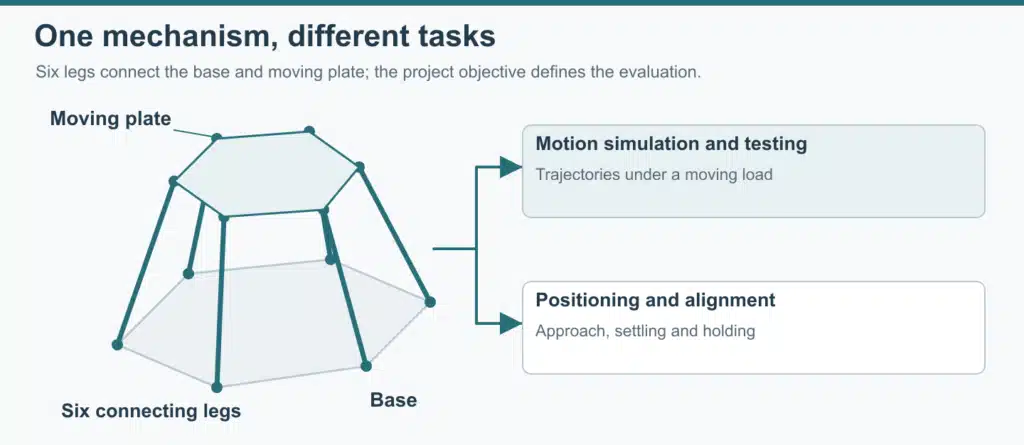
Compare hexapod and Stewart platform requirements for motion simulation and positioning, then define the load case and validation your project needs.